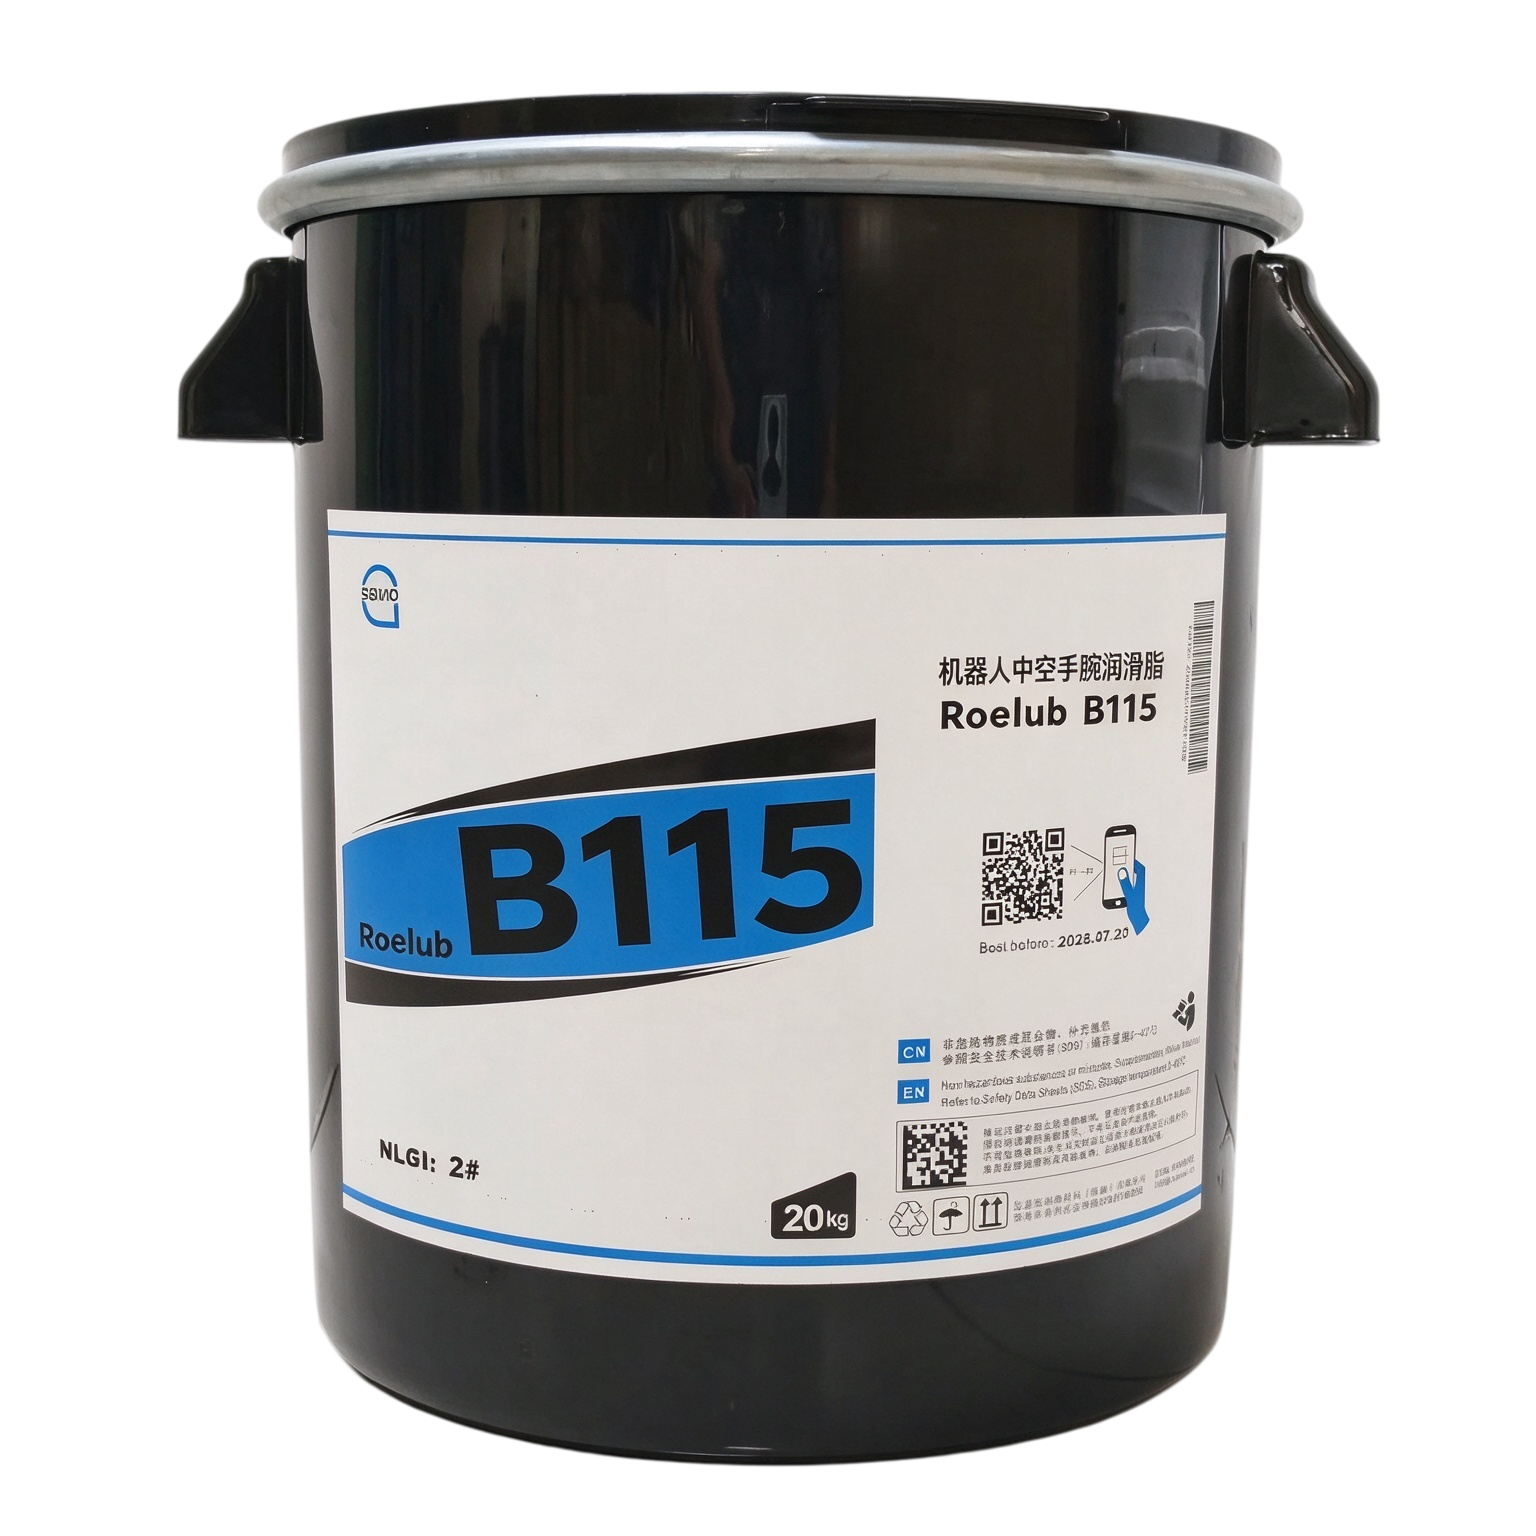
Roelub B115
Robot hollow wrist grease
Description:
SEIVIO Roelub B115 Robot Hollow Wrist Grease is refined from high-performance synthetic base oil, thickened with complex soap, and added with special anti-corrosion additives. It is a special high-performance synthetic grease specially customized for the fourth, fifth, and sixth joints (R/B axis hollow wrist) of industrial six-axis robots. The core is suitable for extreme working conditions of narrow hollow cavities, strong centrifugal force, and frequent reversals. It prevents the grease from being thrown out and contaminating internal cables and encoders, and ensures micron-level transmission accuracy of the wrist and long-term maintenance-free operation.
Benefits:
- Excellent shear stability: Wrist joint torque attenuation rate ≤3.8% after 2 million cycles;
- It will not be easily thrown away or dripped when rotating, and will not flow into the hollow channel to pollute the cable;
- Low starting torque and low noise: ensure sensitive response to wrist movements and reduce joint jitter and noise;
- Compatible with oil seals, plastics, and cable jackets, it will not corrode seals and internal pipelines.
Product specifications:
Performance | data |
color | Visual inspection |
texture | smooth |
smell | mild |
specific gravity,@ 77°F(25°C) | 0.89 |
Drop point,ASTM D-2265 | >200 |
viscosity,cSt @ 40℃ | 100 |
cone penetration,ASTM D-217 @ (25℃) | 265-295 |
four ball test, ASTM D2596,N | 3000 |
operating temperature,℃ | -40~160 |
Shelf life (unopened and fully sealed) | 5 years |
The data provided are typical representative values.Adjustments may be made during normal production that do not affect product performance, and the information contained herein is subject to change without notice. |
Applications:
It is suitable for the R-axis (rotation) and B-axis (swing) of the hollow wrist at the end of the six-axis robotic arm, and is equipped with an RV cycloidal reducer, spherical bearing, and balance bar mechanism. The robot wrist is mainly used to determine the posture of the grasped object. It generally uses a three-degree-of-freedom multi-joint mechanism composed of a rotating joint and a swing joint. The three joints can form 27 configurations. A component used between the robot arm and the gripper to support and adjust the gripper. Developed to be used as a hollow wrist for the R-axis and B-axis of six-axis robots.
Packaging:
1kg/can Order number 230229
20kg/drum Order number 230228
Storage:
Store in a dry place.


 粤公网安备44040202001700号
